Summary of AN INTERESTING CIRCULAR STEWART PLATFORM
This article describes a unique circular Stewart platform featuring six geared motors and arms engaging an internal gear, controlled by an Arduino Pro Mini. The design allows for continuous rotation via a central slip-ring connector alongside standard six degrees of freedom.
Parts used in the Circular Stewart Platform:
- Six geared motors
- Arms with bearings on the central shaft
- Large internal gear
- Six linkages
- Twelve ball joints
- Brackets
- Central slip-ring connector
- Arduino Pro Mini
- Pololu TB6612 dual H-bridge driver modules
Stewart platforms are pretty neat, and not seen in the wild all that often, perhaps because there aren’t a vast number of hacker-friendly applications that need quite this many degrees of freedom within such a restricted movement range. Anyway, here’s an interesting implementation from the the curiously named [Circular-Base-Stewart-Platform] YouTube channel (no, we can’t find the designer’s actual name) with a series of videos from a few years ago, showing the construction and operation of such a beast. This is a very neat mechanism comprised of six geared motors on the end of arms, engaging with a large internal gear. The common end of each arm rides on the central shaft, each with its own bearing. With the addition of the usual six linkages, twelve ball joints, and a few brackets, a complete platform is realised.
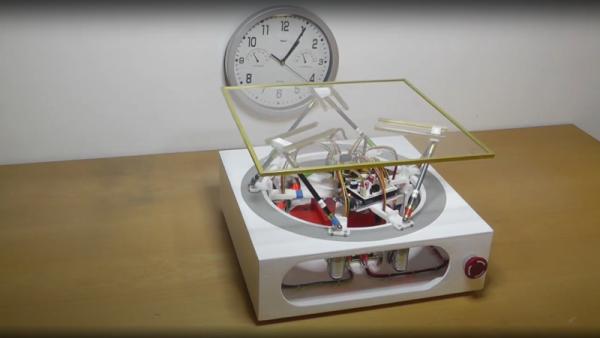
This circular arrangement is so simple that we can’t believe we haven’t come across it before. One interesting deviation from the usual Stewart platform arrangement is the use of a central slip-ring connector to provide power, allowing the whole assembly to rotate continuously, in addition to the usual six degrees of freedom the mechanism allows. Control is courtesy of an Arduino Pro Mini, which drives the motors using a handful of Pololu TB6612 (PDF) dual H-bridge driver modules. Obviously, the sketch running on the Arduino will give the thing a fixed motion, but add in an additional data link over that central slip-ring setup (or maybe a wireless link), and it will be much more useful.
We recently saw another 6-DOF actuator design, using flexures, yet another ball-balancing hack, but if you want an actually useful Stewart platform application, checkout this pool-playing robot!
Source: AN INTERESTING CIRCULAR STEWART PLATFORM
-
What makes this circular arrangement unique?
It uses a central slip-ring connector to provide power, allowing the assembly to rotate continuously. -
How many degrees of freedom does the mechanism allow?
The mechanism allows for six degrees of freedom in addition to continuous rotation. -
What component drives the motors in this project?
An Arduino Pro Mini drives the motors using Pololu TB6612 dual H-bridge driver modules. -
How are the arms connected to the central shaft?
The common end of each arm rides on the central shaft, with each having its own bearing. -
What is used to connect the six linkages to the arms?
Twelve ball joints are used along with six linkages and brackets to realize the complete platform. -
Can the platform be controlled wirelessly?
Yes, adding a wireless link or data link over the central slip-ring setup would make it more useful. -
What type of gears are engaged by the motors?
The motors engage with a large internal gear.
