Summary of Tertiarm – 3d Printed Robot Arm
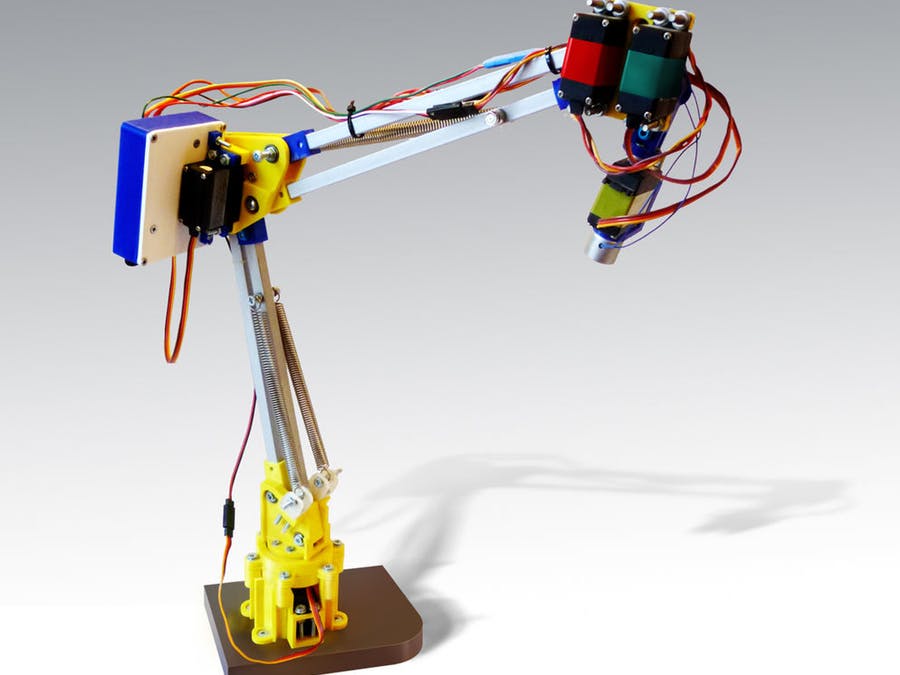
This article introduces Tertiarm, a low-cost 5 DOF robot arm based on an IKEA Tertial lamp. It features a spring-based system to reduce servo load and offers adjustable lifting power. The project involves disassembling the lamp, cutting beams to 260mm, and assembling 3D printed parts like MainPart and ServoTip with various screws and nuts.
Parts used in Tertiarm:
- IKEA Tertial lamp (beams and springs)
- 3D printed MainPart.STL
- 3D printed Tip
- 3D printed ServoTip.STL
- Servo motors
- M3 screws (20mm, 30mm, 10mm)
- M4 screws
- M3 nuts (6 pieces)
- BearingTop.STL
- Wood piece for base mounting
This is first version of my low cost 3d printed robot arm. It is based on Ikea Tertial lamp. I choose it because it has very good kinematic with using springs to unload servos. So you can use different number of springs to achive diffrent lifting power.
Techinacal specification:
- 5 DOF.
- Full lenght: 690mm
- Lifting power with 4 standart spring: 0.5kg (distance between base and attaching point: 500mm)
You can find some information and download STL files for free at:
Step 1: Let’s get it started!
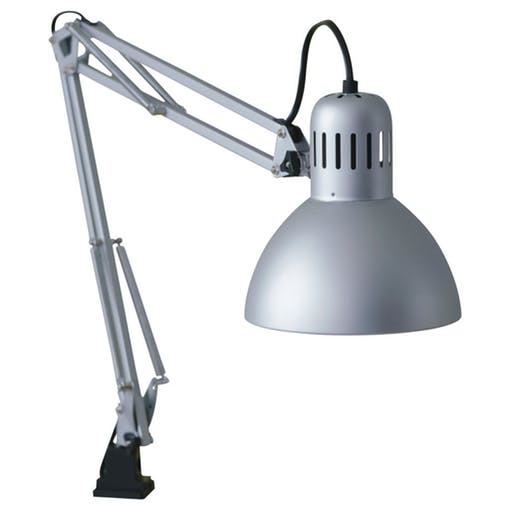
First of all you should take a look at BOM file and picture to get information about all components.
Your can find all information about infill and quantity of 3d printed parts there. Because Tertiarm use lamp as base you won’t need to print big parts, so I hope it can be printed almost at all 3d printers. When you will be ready to start assembly Tertiarm, you should begin from disassembling lamp. You will need only 4 beam and 4 sping, if you be able to find same beams and springs you can do without buing ikea lamp. After making first prototypes, I have decided to cut all beam to 260mm, but you can choose other lenghth depends on your servo and goals.
- Cut all beam to one lenght.
- You should mount Tip and ServoTip 3d printed parts, as it shown on picture. Be careful about it you should check position of all elements. You will need to use mallet to fit it in place, it should be very tight, but you can also add screw to fix it.
- Fix servo horn on ServoTip.STL with M3 screws (20mm)
Now you are ready to assemble 1 axis.
Step 2: 1 Axis
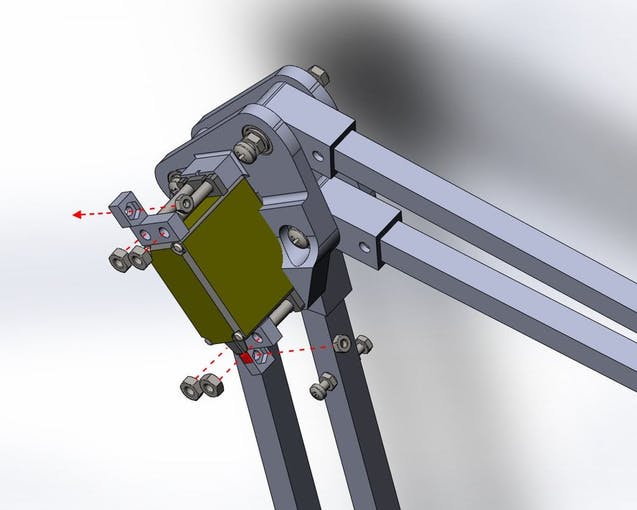
- You will need to insert servo in MainPart.STL. And fix it with 2 scews.
- Fix MainPart.STL to some peice of wood with 7 screws.
- Insert 6 M3 nuts in BearingTop.STL. If it will be too tight you can heat up nuts.
- Assemble axis as shown on picture using 2 M3 screws (30mm).
- Insert 6 m3 screw (10mm).
- Mount it at MainPart.STL using 6 M4 screws. Make sure you have mount serrvo horn to servo and fix it with m3 screw (30mm) in center hole to servo.
- You have assemled 1 axis!
Read More: Tertiarm – 3d Printed Robot Arm
- How many degrees of freedom does this robot arm have?
The robot arm has 5 degrees of freedom. - What is the full length of the Tertiarm robot arm?
The full length is 690mm. - Can I build this without buying the IKEA lamp?
Yes, you can use different beams and springs if you find compatible ones. - What length should the beams be cut to?
The author suggests cutting all beams to 260mm, though other lengths work depending on goals. - How do you secure the servo horn to the ServoTip?
You fix the servo horn on ServoTip.STL using M3 screws that are 20mm long. - How do you assemble the first axis?
Insert the servo into MainPart.STL, fix it with two screws, mount the part to wood, and attach BearingTop.STL with M4 screws. - What happens if the M3 nuts fit too tightly in BearingTop.STL?
You can heat up the nuts to make them fit easier. - Where can I download the STL files for free?
The STL files are available on Thingiverse and Hackaday.
